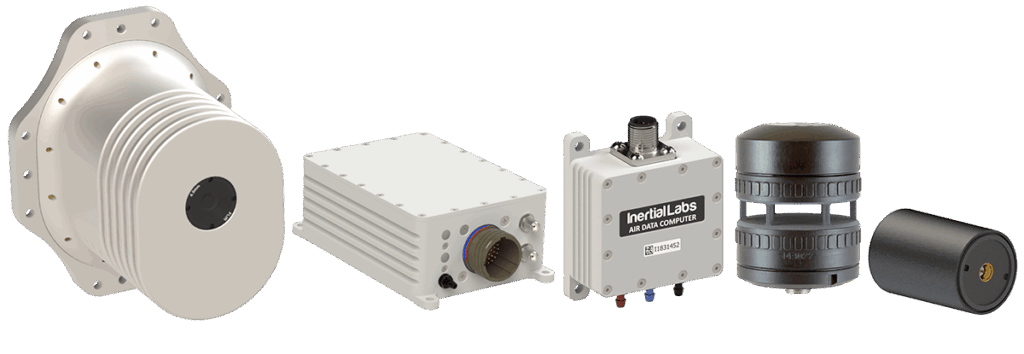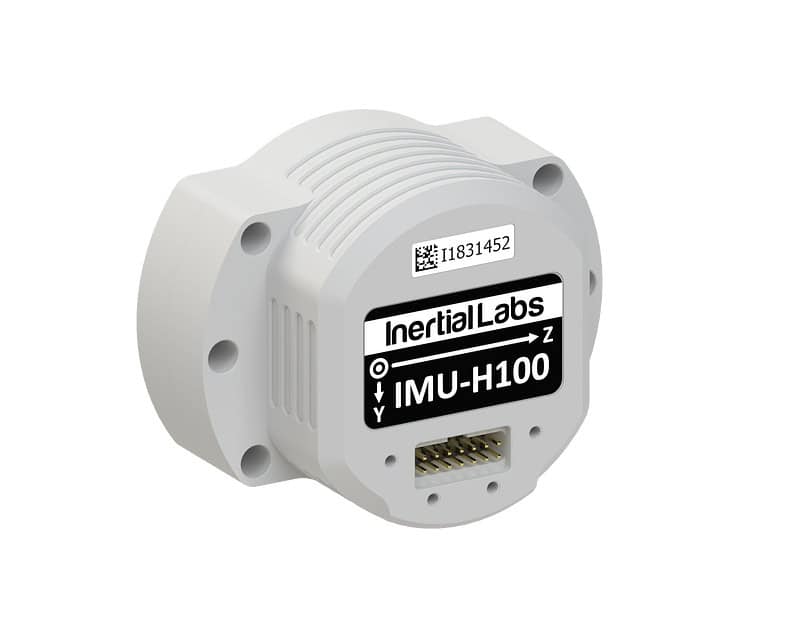
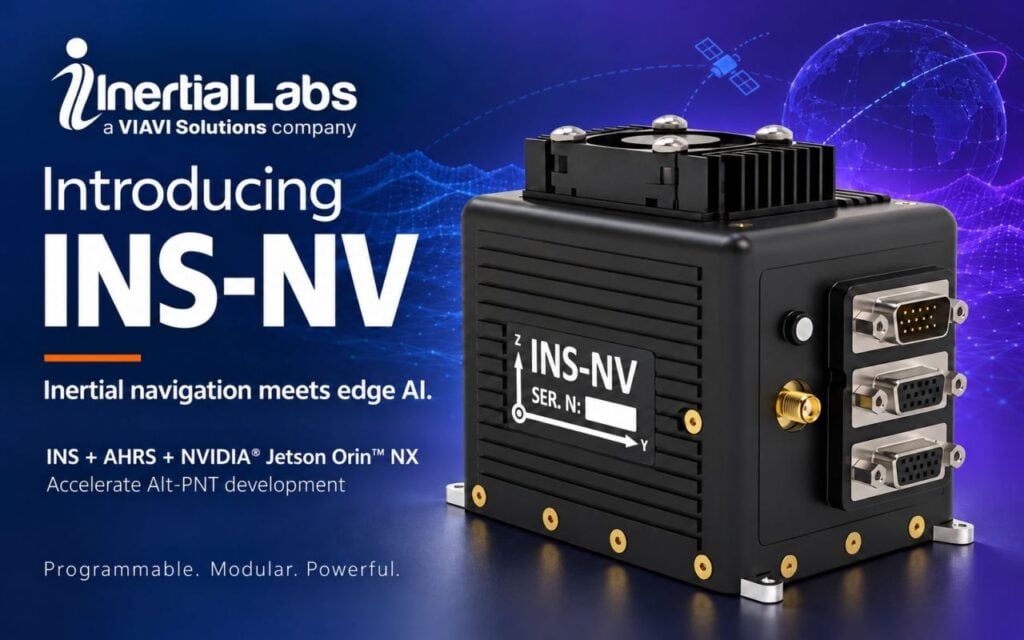
Inertial Labs, a VIAVI Solutions company, has launched the INS-NV, a programmable development platform integrating inertial navigation and edge AI processing to accelerate the development of Alternative Positioning, Navigation, and Timing (Alt-PNT) systems.
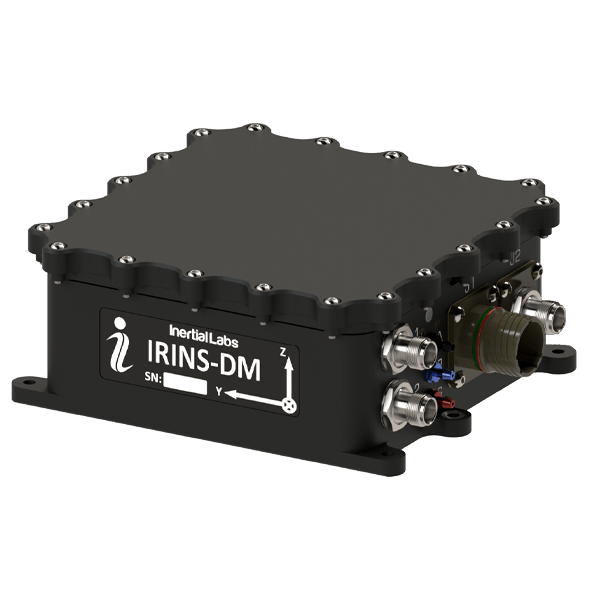
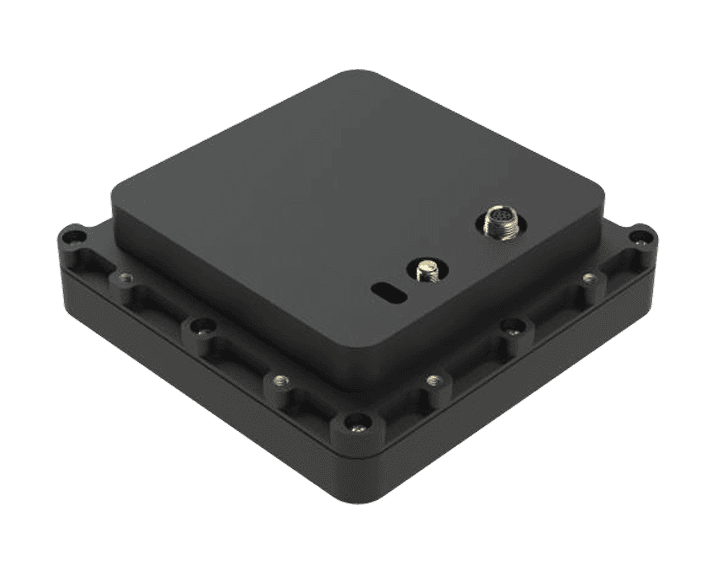
The modular platform combines an Inertial Navigation System (INS), an Attitude and Heading Reference System (AHRS), and an NVIDIA Jetson Orin NX module. This architecture allows developers to run machine vision and navigation algorithms alongside the INS and AHRS technologies, reducing the time required to integrate INS systems and software.
Designed to support real-time navigation and sensor fusion in highly dynamic GNSS-denied and compromised environments, the INS-NV incorporates fully calibrated tactical-grade MEMS accelerometers and gyroscopes, magnetometers, a barometric altimeter, and a full-constellation GNSS receiver supporting GPS, QZSS, GLONASS, Galileo, BeiDou, and NavIC.
The platform also uses Inertial Labs’ aiding data ecosystem, sensor fusion filters, calibration software, and navigation algorithms to provide precise time, position, velocity, and attitude measurements. Its expandable architecture supports the integration of additional Inertial Labs sensor modules and commercial off-the-shelf vision cameras.
Jamie Marraccini, Vice President, Inertial Labs Products at VIAVI, said, “Visual navigation needs continuous information about vehicle position, orientation and time. Because these systems have traditionally lacked a high-end processor, developers have to spend considerable R&D time and budget to integrate their software with the INS, and that’s before they build a platform.”
“The advanced sensor fusion addresses this challenge, enabling developers to run their own visual navigation stacks alongside our INS and AHRS technologies, and more quickly create advanced alternative navigation and PNT systems.”
The INS-NV is available immediately, with MAVLink, ASPN-, pntOS- and MOSA-compliant variants available on request.