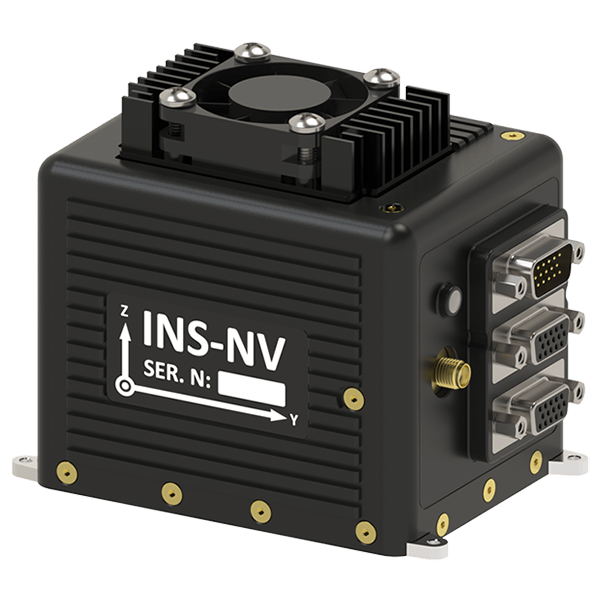
The Inertial Labs INS-NV is a programmable inertial navigation development platform combining an Inertial Navigation System (INS), Attitude and Heading Reference System (AHRS), and NVIDIA Jetson compute module in a modular architecture.
Designed for computationally demanding navigation and sensor-fusion development, it provides a platform for machine-vision algorithms, autonomous guidance systems, alternative positioning, navigation, and timing (APNT) processing, and other real-time navigation workloads.
Fully calibrated tactical-grade MEMS accelerometers and gyroscopes operate alongside a full-constellation GNSS receiver supporting GPS, QZSS, GLONASS, Galileo, BeiDou, and NavIC, with an embedded barometric altimeter, in-flight magnetometer calibration, and an ASPN-compliant data interface available upon request.
INS-NV uses Inertial Labs' sensor-fusion filters, calibration capabilities, navigation algorithms, and external aiding architecture to generate precise position, velocity, attitude, and timing outputs while preserving accurate orientation when GNSS is unavailable. Its expandable sensor-fusion design supports external aiding inputs and compatibility with commercial off-the-shelf cameras or Inertial Labs Sensor Modules, while access to raw GNSS measurements and IMU data enables post-processing workflows.
MIL-STD-810G compliance supports operation under demanding conditions, while the integrated compute and navigation architecture helps shorten system-integration cycles for developers building robust guidance, autonomy, and assured-navigation solutions.