Underwater tracking systems locate and monitor divers, AUVs, ROVs, subsea equipment, and other submerged assets where GNSS signals are unavailable. Technologies include USBL, SBL and LBL acoustic positioning, pingers, surface-tethered GNSS, optical and laser tracking, and electromagnetic or magnetic methods.
This category showcases suppliers of underwater tracking devices and solutions for subsea surveillance, infrastructure inspection, asset recovery, and coordinated autonomous missions.
If you design, build or supply Underwater Tracking Systems, create a profile to showcase your capabilities and connect with visitors who have an active requirement for your solutions.
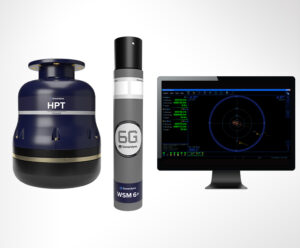
USBL tracking, dynamic positioning & subsea telemetry system
USBL tracking, dynamic positioning & subsea telemetry system
...is a versatile underwater positioning, tracking, and telemetry system developed for subsea survey,... ... and demanding underwater environments, Ranger 2 supports simultaneous tracking of up to 99 targets...
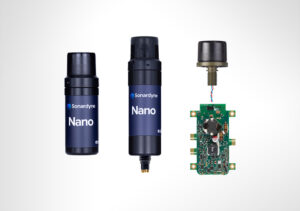
Compact acoustic transceiver for AUV tracking, communications & navigation aiding
Compact acoustic transceiver for AUV tracking, communications & navigation aiding
...for Autonomous Underwater Vehicles (AUVs) requiring tracking, telemetry, navigation aiding, and... ...00 metres, the system provides tracking and communication ranges of up to 3,000 metres with range...
USBL tracking, positioning & underwater communications system for marine robotics
USBL tracking, positioning & underwater communications system for marine robotics
...L is a compact underwatertracking, positioning, and communications system developed for offshore... ...echnology, the system delivers reliable positioning and telemetry performance even in challenging...
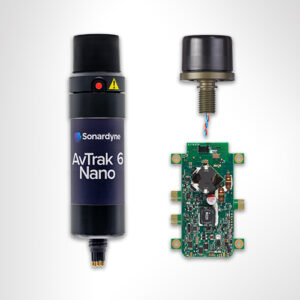
Compact USBL transponder for underwater tracking & subsea positioning
Compact USBL transponder for underwater tracking & subsea positioning
... developed for underwatertracking, positioning, and acoustic communication across AUV, ROV, diver,... ...in challenging underwater environments. Available in NFC, connector, and OEM variants, the...
Submersible AIS-compatible recovery beacon for maritime asset retrieval
Submersible AIS-compatible recovery beacon for maritime asset retrieval
...or short-range tracking and recovery of submerged defense assets. Operating as an AIS Aid to... ...leep mode when underwater and activates at the surface to begin transmitting. Configuration is...
Overview of Underwater Tracking Systems for Subsea Asset Monitoring
Overview by
William Mackenzie
Updated:
Introduction to Underwater Tracking Systems
Underwater tracking systems locate and monitor divers, Unmanned Underwater Vehicles (UUVs), Remotely Operated Vehicles (ROVs), subsea equipment, and other submerged assets. Because satellite navigation signals do not propagate effectively through seawater, an underwater tracking system typically relies on acoustic, optical, electromagnetic, surface-referenced, or onboard inertial technologies to establish or estimate position and movement.
For defense and security operations, underwater tracking can support vehicle navigation, diver safety, subsea surveillance, infrastructure monitoring, and coordinated autonomous missions. The appropriate underwater tracking device depends on factors including operating range, water depth, environmental conditions, required accuracy, update rate, deployment geometry, and integration with existing navigation and command systems.
Types of Underwater Tracking Systems
Ultra-Short Baseline (USBL) Tracking Systems
USBL systems use a compact transducer array, typically mounted on a vessel or deployed from a surface platform, to determine the range and bearing of a subsea transponder. USBL underwater tracking can provide real-time positioning for ROVs, Autonomous Underwater Vehicles (AUVs), divers, and deployed equipment without requiring a large seabed array. Accuracy can be affected by sound-speed variation, acoustic multipath, platform motion, and transducer calibration.
Short Baseline (SBL) Tracking Systems
SBL systems use multiple hydrophones separated across a surface vessel or other platform. By comparing acoustic measurements between these receivers, an SBL system calculates the position of a submerged target. The larger physical baseline can provide useful positioning performance, although installation geometry, vessel configuration, synchronization, and environmental conditions influence accuracy.
Long Baseline (LBL) Tracking Systems
LBL systems establish an array of acoustic transponders on the seabed around an operating area. A tracked vehicle or underwater tracker measures ranges to these known reference points to calculate position. LBL is particularly useful where accurate, repeatable subsea positioning is required independently of continuous surface-vessel proximity, although the reference array must normally be deployed and surveyed before operations.
GPS Surface-Tethered Tracking Systems
GPS signals do not work effectively underwater. Instead, underwater GPS tracking systems can use a GPS-equipped surface buoy connected to the diver or submerged asset. The buoy provides the surface position, while additional sensors can be used to estimate the position underwater.
Acoustic Pingers
Acoustic pingers transmit identifiable sound pulses that can be detected by hydrophones or direction-finding equipment. These underwater tracking aids are commonly suited to locating equipment, vehicles, payloads, or recovery targets. A basic pinger may provide detection or bearing information, while range or absolute position generally requires additional receivers, timing information, or positioning geometry.
Subsea Optical and Laser Tracking Systems
Optical cameras and laser-based sensors can support precise underwater motion tracking at relatively short ranges. They may be used for close-proximity vehicle control, docking, manipulation, inspection, or relative positioning. Performance depends strongly on water clarity because suspended particles, scattering, and absorption restrict optical operating range.
Subsea Electromagnetic and Magnetic Tracking Systems
Electromagnetic and magnetic techniques can detect or locate suitably equipped targets without relying on acoustic propagation. Electromagnetic systems can provide relative positioning using generated fields, while magnetic sensors can detect magnetic sources or anomalies. Their practical range is generally limited by seawater attenuation, field strength, and sensor geometry, but they can be valuable for specialized close-range tracking, docking, buried-object detection, and operations where acoustic methods are unsuitable.
Components of an Underwater Tracking System
The architecture of an underwater acoustic tracking system varies according to the positioning method, but several components are commonly integrated into defense, survey, and unmanned-system installations.
Acoustic transponders and responders: Subsea units receive interrogations or external triggers and transmit acoustic replies that allow tracking equipment to calculate range, identity, or position.
Transceivers and interrogators: These units generate, transmit, receive, and process the acoustic signals exchanged with underwater tracking devices.
Hydrophone and transducer arrays: Acoustic sensing elements detect incoming signals and, in USBL or SBL systems, help determine the direction or relative position of the tracked target.
Surface and subsea reference stations: Known or continuously measured reference points establish the positioning geometry against which vehicle, diver, or subsea asset movement can be calculated.
GNSS and inertial reference sensors: Surface GNSS, heading sensors, motion reference units, and inertial systems provide the position and attitude information needed to transform acoustic measurements into useful coordinates.
Processing units and tracking software: Computing systems combine sensor measurements, apply calibration, sound-speed, motion, and environmental corrections, display tracks, and distribute position information to mission or navigation systems.
Together, these elements allow raw acoustic or sensor measurements to be converted into actionable position and movement data.
Core Applications of Underwater Tracking Systems
Tracking Unmanned Underwater Vehicles
AUV tracking and positioning provide operators with awareness of vehicle location during missions in which direct satellite navigation is unavailable. Acoustic tracking can complement onboard inertial navigation and Doppler Velocity Log (DVL) measurements, while an ROV tracker can provide continuous surface-referenced positioning during inspection, intervention, mine countermeasures, or reconnaissance tasks.
Diver and Swimmer Tracking
Military and public-safety diving operations can use underwater tracking devices to monitor individual divers or swimmer delivery activities. Position information can improve surface-team awareness, assist mission coordination, and support recovery procedures when personnel are operating in low visibility, strong currents, or complex underwater environments.
Underwater Asset and Payload Tracking
Underwater asset monitoring can be used to locate deployed sensors, payloads, equipment packages, training targets, or other subsea systems. Tracking may provide position during deployment and recovery or support longer-term monitoring when subsea asset movement must be detected or recorded.
Seabed Infrastructure Monitoring
Subsea tracking technologies can support the inspection and monitoring of cables, pipelines, communications infrastructure, sensor networks, and other seabed installations. Accurate vehicle positioning helps associate collected sonar, optical, or environmental data with specific infrastructure locations and can improve repeatability during subsequent inspection missions.
Subsea Surveillance and Reconnaissance
Underwater tracking can contribute to maritime domain awareness by supporting the localization of friendly vehicles, deployed sensors, and detected underwater contacts. In anti-submarine underwater tracking applications, acoustic sensing and tracking information may form one element of a wider sensor architecture that combines sonar, platform navigation, communications, and command systems.
Emerging Underwater Tracking Device Technologies
Developments in autonomy, distributed sensing, and navigation are driving underwater tracking systems toward more networked and resilient architectures.
Networked acoustic tracking: Distributed transponders, modems, and reference nodes can create wider-area subsea tracking networks that support multiple vehicles or persistent operating zones.
Multi-sensor fusion: Acoustic measurements can be combined with inertial navigation, Doppler velocity, depth, heading, and environmental data to maintain more robust position estimates when individual sensors become degraded or temporarily unavailable.
Low-SWaP tracking systems: Smaller, lighter, and more power-efficient tracking electronics can reduce Size, Weight, and Power (SWaP) requirements for compact AUVs, expendable platforms, distributed sensors, and vehicles with limited payload capacity.
Resilient navigation: Acoustic tracking can be integrated with inertial, terrain-relative, optical, and other alternative navigation methods to reduce dependence on any single positioning source in GNSS-denied or contested environments.
These developments are also important for AUV swarm tracking, where multiple autonomous platforms may need to maintain awareness of their own positions and the relative locations of other vehicles while operating cooperatively.
Advancing Defense Capability Through Strategic Collaboration
Defense Advancement works with major OEMs to foster collaboration and increase engagement with SMEs, to accelerate innovation and drive defense capabilities forward.