GNSS spoofing presents a significant challenge to autonomous and defense systems operating in contested environments, where manipulated satellite signals can compromise positioning and navigation. Advanced Navigation examines the techniques used to deceive GNSS receivers and the role of Electronic Protection, inertial navigation systems (INS), and complementary aiding sensors in maintaining resilient navigation when satellite signals are compromised.
How GNSS Spoofing Compromises Navigation
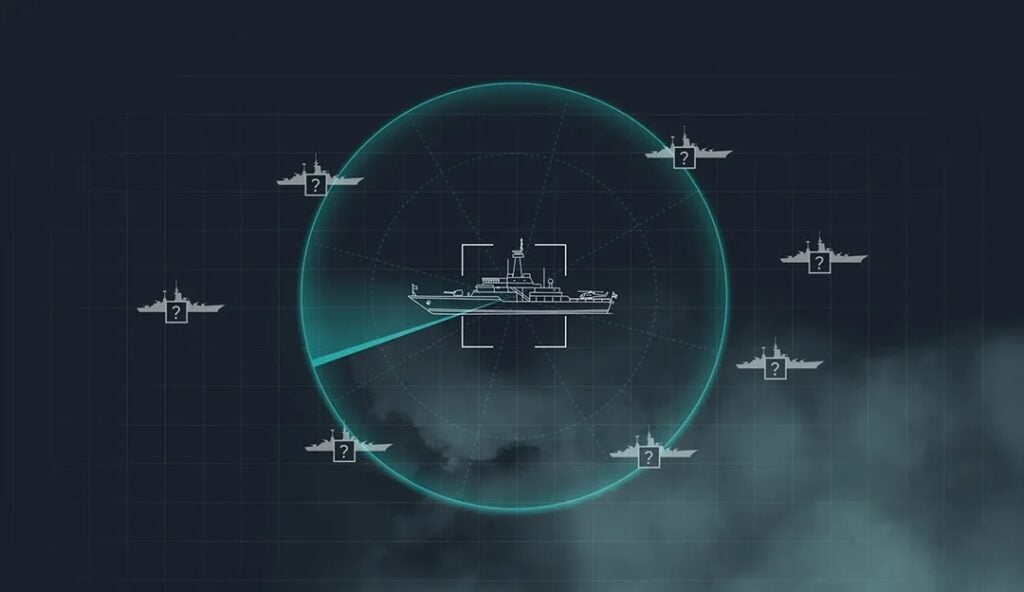
Unlike jamming, which disrupts signal reception, spoofing attempts to deceive a GNSS receiver by transmitting false signals that closely resemble authentic satellite transmissions.
The objective is to cause the receiver to unknowingly calculate an incorrect position or time. By manipulating the information used to determine location, attackers can introduce errors in both horizontal and vertical positioning, potentially causing unmanned aerial vehicles (UAVs) and unmanned surface vehicles (USVs) to deviate from their intended routes.
The complexity of these attacks varies considerably, from relatively straightforward signal replay techniques to theoretical methods intended to affect multiple autonomous platforms across a wide area.
Understanding Different GNSS Spoofing Techniques
Several spoofing methods can be used to manipulate satellite-based positioning, with differences in their technical complexity, synchronization requirements, and implementation.
Replay attacks represent one of the more basic approaches. These involve recording an authentic satellite signal and retransmitting it at a higher power level to cause the GNSS receiver to lock onto the replayed transmission.
Selective delay attacks introduce controlled delays into individual satellite signals. These adjustments can produce small, plausible changes in the receiver’s calculated position, making the resulting errors less immediately apparent.
Jam and spoof attacks use two transmitters to interfere with authentic satellite signals while simultaneously introducing fabricated signals. This combined approach increases the technical complexity compared with basic replay or delay methods.
The liftoff method requires more precise signal synchronization. An attacker initially aligns a spoofed satellite signal with the genuine transmission before gradually increasing its power. The objective is to transfer the receiver’s tracking from the authentic signal to the fabricated one without an abrupt transition.
Spatial or wide-area spoofing represents a more complex, theoretical approach. As of mid-2026, this technique remained in research and development. It seeks to emulate satellite transmissions across a broad geographic area, potentially allowing multiple receivers, including those used by drone swarms, to be deceived in a coordinated manner.
These complexity classifications reflect the technical barriers to implementation, the precision required, and whether the techniques have been demonstrated in operational conditions or remain theoretical.
Addressing Misconceptions About Spoofing Protection
Effective GNSS protection requires an understanding of the limitations associated with individual countermeasures.
One common misconception is that an attacker must first jam authentic satellite signals before spoofing can occur. In practice, techniques such as liftoff attacks can introduce false signals without initial jamming, making interference more difficult to identify.
Signal authentication also does not eliminate every vulnerability. Although authentication and encryption provide additional protection, replay attacks can still exploit genuine satellite signals by recording and retransmitting them.
Another misconception is that spoofing transmissions necessarily originate from fixed, ground-based equipment. Attackers can also operate from mobile or airborne platforms, limiting the effectiveness of passive smart antennas configured specifically to suppress interference arriving from ground-level sources.
These distinctions highlight why protection against spoofing cannot depend on a single antenna configuration, authentication mechanism, or signal-monitoring technique.
A Layered Approach to GNSS Spoofing Mitigation
Navigation resilience depends on combining multiple protective technologies that address different aspects of signal interference and positioning integrity.
A layered architecture incorporates antenna-level protection, receiver-based anomaly detection, inertial navigation, and additional sensing capabilities. Each component contributes a different form of protection or navigation continuity when GNSS signals become unreliable.
Antenna-Level Protection Against Interference
The first layer of defense operates at the antenna.
Passive antennas can reduce the strength of interference originating from ground-based transmitters, limiting the influence of some spoofing and jamming attempts before the signals reach the receiver.
Active antenna systems provide additional capabilities through spatial signal processing. By tracking the direction of interference sources, these systems can apply techniques that nullify or cancel unwanted transmissions.
The effectiveness of antenna-based protection depends partly on the characteristics and origin of the interfering signal, making it one component of a broader mitigation strategy rather than a standalone solution.
Detecting Signal Anomalies with Electronic Protection Receivers
A second layer introduces signal-level monitoring through advanced Electronic Protection receivers.
These receivers analyze incoming GNSS signals for anomalies that may indicate manipulation. When spoofing is detected, the receiver can reject or drop the affected positioning fix, preventing potentially corrupted information from being incorporated into the navigation solution.
This capability helps distinguish between the availability of a satellite signal and its reliability as a positioning reference.
However, rejecting an unreliable GNSS fix also creates a requirement for alternative positioning information if navigation is to continue without relying on the compromised signal.
Maintaining Positioning Continuity with Inertial Navigation Systems
Inertial navigation systems provide another layer of protection by maintaining position information when GNSS reception is disrupted, jammed, or rejected.
When combined with intelligent sensor fusion, an INS can identify discrepancies between satellite-derived positioning and inertial navigation estimates.
For example, a replay attack may cause a GNSS receiver to indicate that a vehicle has suddenly moved tens of miles or kilometers from its actual position. An INS can recognize this abrupt displacement as an anomaly and switch to the higher-trust inertial navigation position rather than accepting the compromised GNSS information.
This relationship between independent navigation information and GNSS measurements is central to identifying positioning inconsistencies and maintaining navigation continuity.
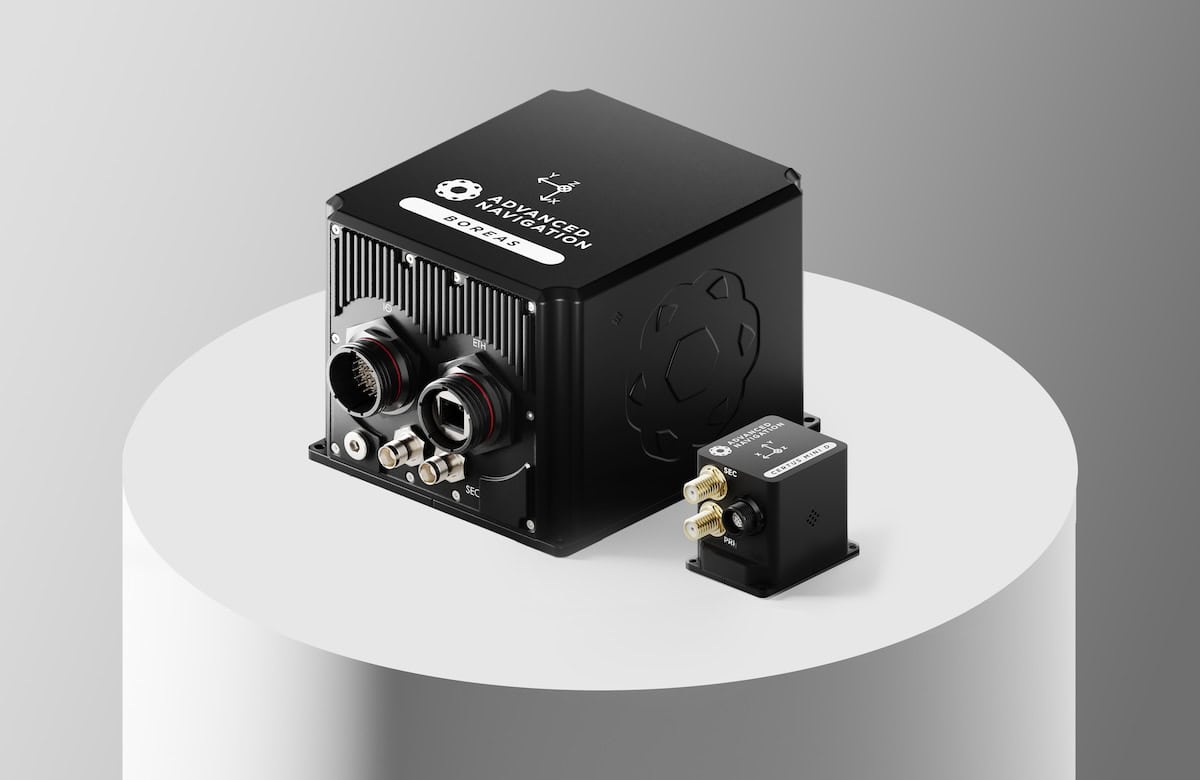
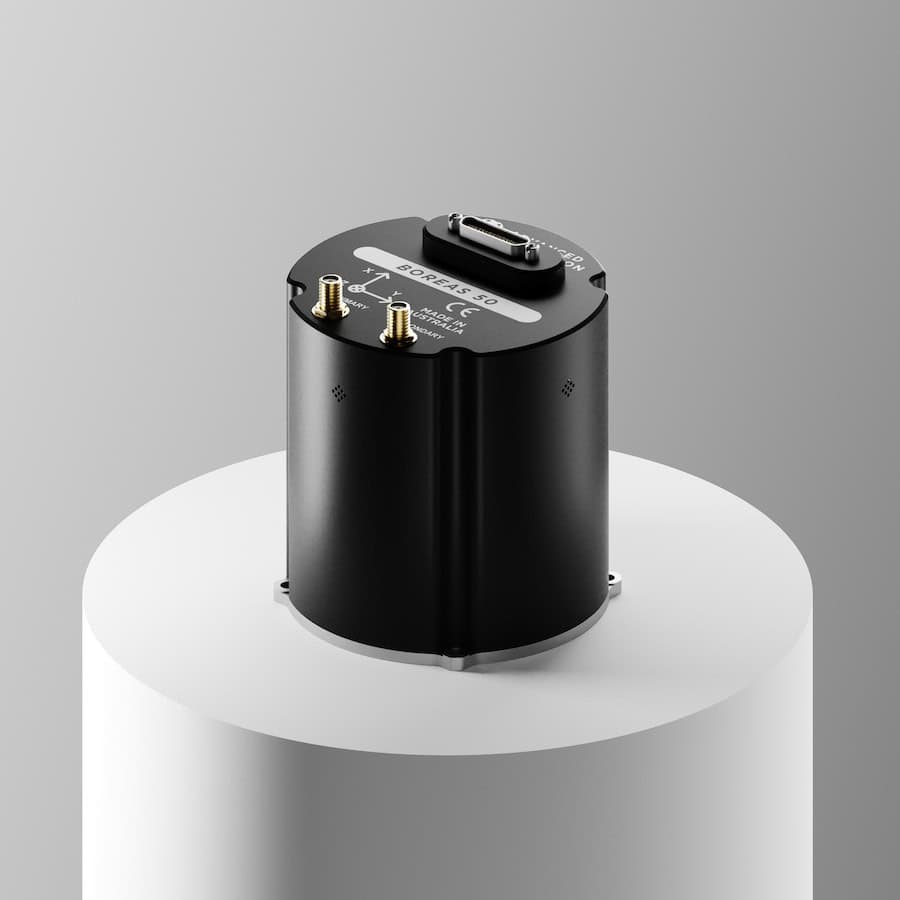
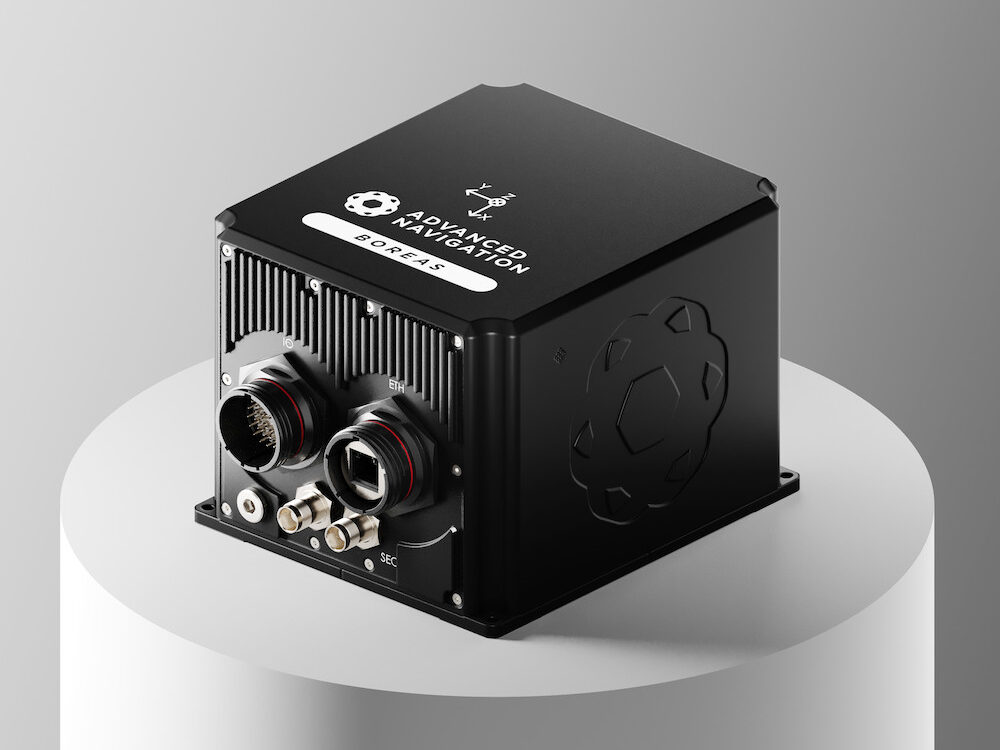
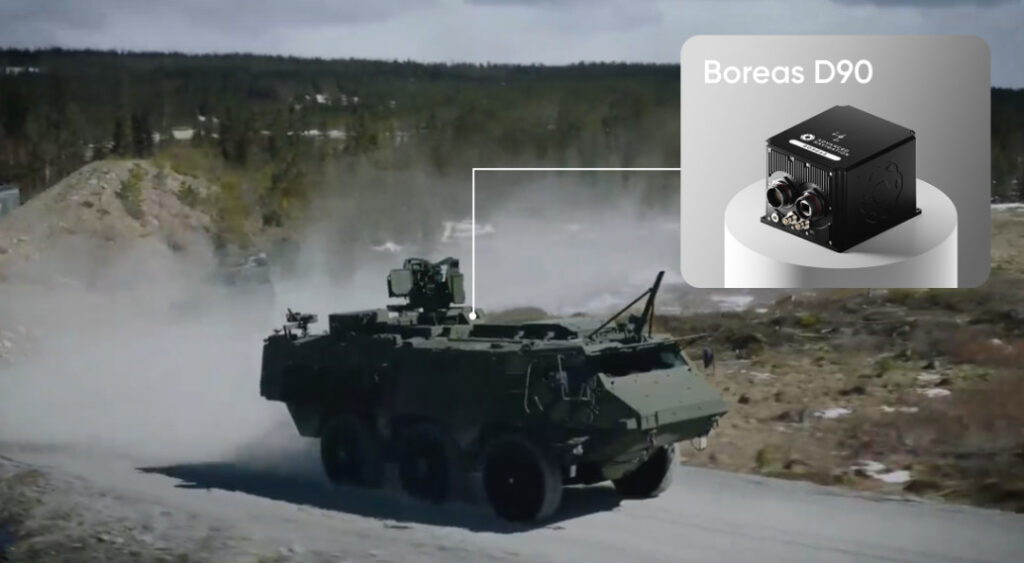
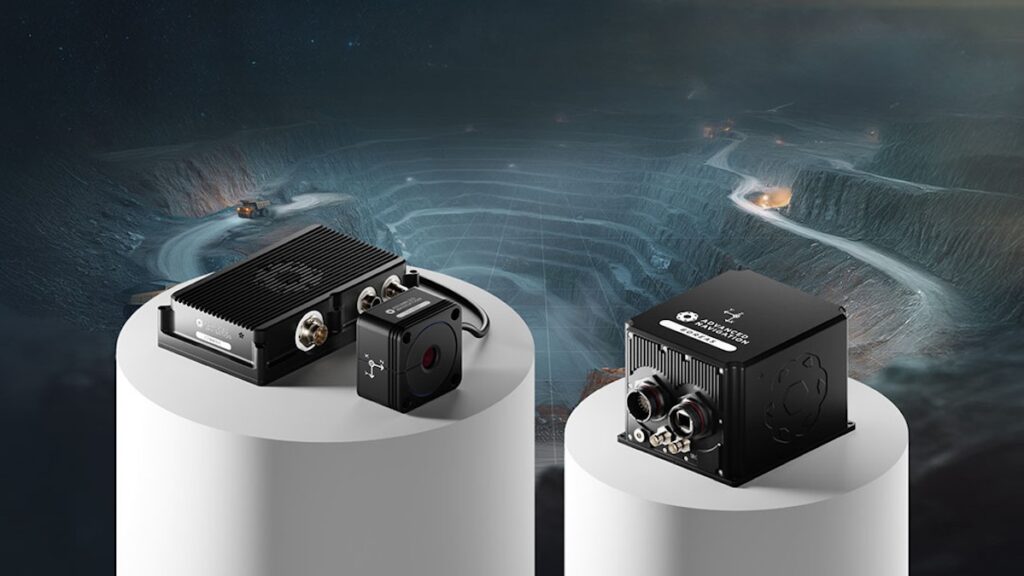
Advanced Navigation’s INS portfolio includes the Certus Evo, Boreas D50, Boreas D70, and Boreas D90. These systems are designed for operation in contested environments with Electronic Protection.
Their role within a layered navigation architecture is to provide inertial positioning information that can be used when GNSS measurements are unreliable or unavailable.
Incorporating Complementary Aiding Sensors
Additional resilience can be achieved by integrating complementary sensing technologies into the navigation architecture.
Optical, magnetic, radar, sonar, and LiDAR sensors provide different sources of information that can support navigation according to the mission requirements and operating environment.
Selecting appropriate aiding sensors allows systems to incorporate redundancy beyond GNSS and inertial measurements.
The suitability of each sensor depends on the platform and its operational conditions, making sensor selection an important consideration for defense, maritime, and autonomous applications.
Combining these technologies can support positioning accuracy, resilience, and adaptability when individual sensors are degraded, denied, or unavailable.
Building Navigation Resilience in Contested Environments
The range of spoofing techniques, from basic replay attacks to more complex signal manipulation, demonstrates the limitations of relying exclusively on GNSS reception or a single protective measure.
Antenna-level interference suppression, receiver-based anomaly detection, intelligent sensor fusion, and independent navigation information address different aspects of the threat.
For autonomous and defense platforms, integrating these capabilities provides a means of reducing dependence on any single positioning source while supporting navigation continuity under degraded or denied GNSS conditions.
Advanced Navigation’s approach brings together Electronic Protection and INS technology as part of this broader, multi-sensor strategy. Complementary aiding sensors can provide further redundancy according to the vehicle, mission, and operating environment.
Further technical discussion of these protection strategies is available in Advanced Navigation’s report, The Threat of Spoofing and Building Resilient Navigation Systems.