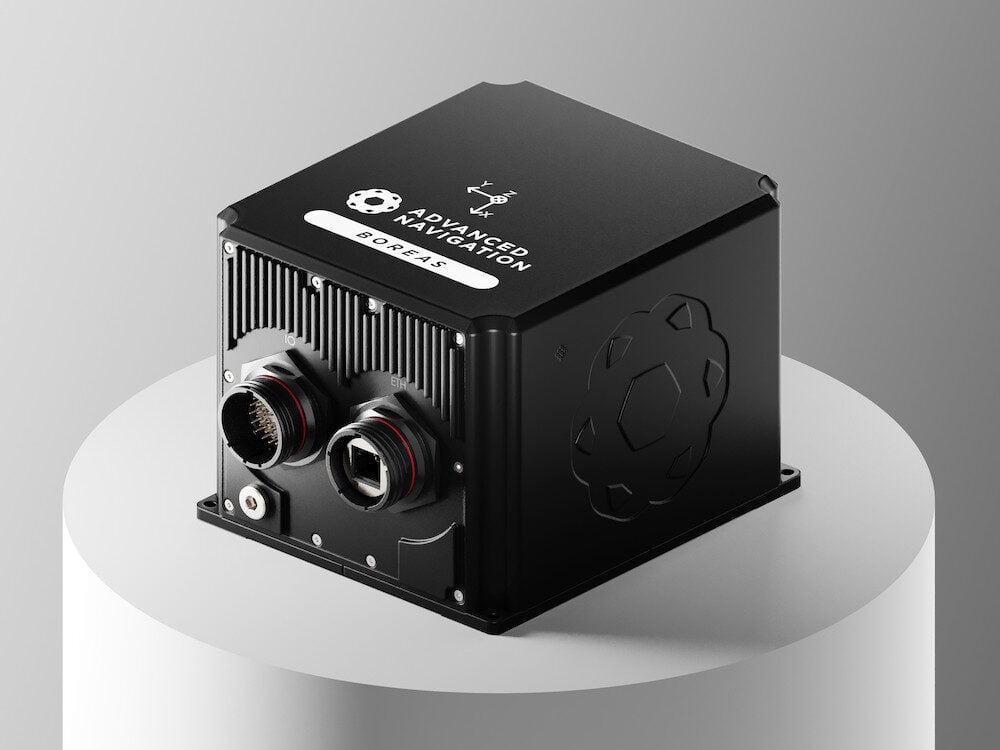
The Boreas A70 and A90 from Advanced Navigation are rugged FOG IMU/AHRS systems engineered to maintain precise heading and orientation when GNSS or magnetic references are unavailable. Digital fibre optic gyroscopes, closed-loop accelerometers, and AI-based sensor fusion enable north-seeking gyrocompassing without reliance on magnetometers or satellite positioning. Both variants provide 2-minute coarse gyrocompassing, output rates reaching 1000 Hz, IP67 environmental protection, and an operating range from -40 °C to 75 °C. A 9–36 V supply range and 12 W typical power consumption also support integration where size, weight, power, and cost are constrained. Full INS functionality can be added, with external GNSS aiding supported when available.
The A70 delivers 0.01° roll and pitch accuracy, 0.1° heading accuracy, and 0.01°/hr gyroscope bias instability, while the A90 increases performance to 0.005° roll and pitch accuracy, 0.01° heading accuracy, and 0.001°/hr gyroscope bias instability. Ethernet, RS232/RS422, CAN, 1PPS, GPIO, and auxiliary RS232 interfaces provide flexible connectivity, alongside support for NMEA, CANopen, AN Packet Protocol, odometer, DVL/USBL, air data, zero-velocity, and external GNSS inputs. Supported applications include unmanned aerial vehicles, autonomous vehicles, gimbal stabilization, surveying, structural monitoring, tunnelling and mining, subsea navigation, infrastructure monitoring, and hydrography.
| Boreas A70 | Boreas A90 | |
| Roll and pitch accuracy: | 0.01° | 0.005° |
| Heading accuracy: | 0.1° secant latitude RMS | 0.01° secant latitude RMS |
| Gyrocompassing alignment: | 2 min coarse; 10 min fine, typical | 2 min coarse; 10 min fine, typical |
| Horizontal position accuracy, external RTK GNSS aided: | 0.01 m | 0.01 m |
| Vertical position accuracy, external RTK GNSS aided: | 0.015 m | 0.015 m |
| Velocity accuracy, external GNSS aided: | 0.005 m/s | 0.005 m/s |
| Heave accuracy: | 2% or 0.02 m, whichever is greater | 2% or 0.02 m, whichever is greater |
| Output data rate: | 1000 Hz | 1000 Hz |
| Interfaces: | Ethernet, RS232/RS422, CAN, 1PPS | Ethernet, RS232/RS422, CAN, 1PPS |
| Ethernet speed: | 100 Mbit | 100 Mbit |
| Serial speed: | 4800 to 4M baud | 4800 to 4M baud |
| Protocols: | AN Packet Protocol, NMEA, CANopen | AN Packet Protocol, NMEA, CANopen |
| Peripheral interfaces: | 2 × GPIO, 1 × auxiliary RS232 | 2 × GPIO, 1 × auxiliary RS232 |
| GPIO level: | 5 V (RS232), 3.3 V | 5 V (RS232), 3.3 V |
| GPIO functions: | 1PPS input/output, odometer input, DVL/USBL input, air data input, zero-velocity input, NMEA input/output, NovAtel GNSS input, Trimble GNSS input, AN Packet Protocol, CAN/CANopen | 1PPS input/output, odometer input, DVL/USBL input, air data input, zero-velocity input, NMEA input/output, NovAtel GNSS input, Trimble GNSS input, AN Packet Protocol, CAN/CANopen |
| Operating voltage: | 9 to 36 V | 9 to 36 V |
| Input protection: | -200 to 200 V | -200 to 200 V |
| Typical power consumption: | 12 W | 12 W |
| Hot-start standby duration: | — | 48 hrs |
| Operating temperature: | -40 °C to 75 °C | -40 °C to 75 °C |
| Environmental protection: | IP67 | IP67 |
| MTBF: | >70,000 hrs | >70,000 hrs |
| Shock limit: | 50 g, 11 ms, MIL-STD-810H | 50 g, 11 ms, MIL-STD-810H |
| Vibration: | 8 g RMS, 20–2000 Hz random | 8 g RMS, 20–2000 Hz random |
| Dimensions: | 160 × 140 × 115.5 mm | 160 × 140 × 115.5 mm |
| Weight: | 2.7 kg | 2.7 kg |
| Accelerometer range: | ±15 g | ±15 g |
| Gyroscope range: | ±490 °/s | ±490 °/s |
| Pressure sensor range: | 10 to 130 kPa | 10 to 130 kPa |
| Accelerometer bias instability: | 7 µg | 7 µg |
| Gyroscope bias instability: | 0.01 °/hr | 0.001 °/hr |
| Pressure bias instability: | 8 Pa | 8 Pa |
| Accelerometer initial bias: | <100 µg | <100 µg |
| Gyroscope initial bias: | <0.05 °/hr | <0.01 °/hr |
| Pressure initial bias: | <50 Pa | <50 Pa |
| Accelerometer initial scaling error: | 340 ppm | 340 ppm |
| Gyroscope initial scaling error: | 100 ppm | 80 ppm |
| Accelerometer scale factor stability: | 150 ppm | 100 ppm |
| Gyroscope scale factor stability: | 20 ppm | 10 ppm |
| Accelerometer non-linearity: | 150 ppm | 150 ppm |
| Gyroscope non-linearity: | 10 ppm | 10 ppm |
| Cross-axis alignment error: | <0.001° accelerometers; <0.001° gyroscopes | <0.001° accelerometers; <0.001° gyroscopes |
| Accelerometer noise density: | 40 µg/√Hz | 30 µg/√Hz |
| Gyroscope noise density: | 0.3 °/hr/√Hz | 0.06 °/hr/√Hz |
| Pressure noise density: | 0.4 Pa/√Hz | 0.4 Pa/√Hz |
| Accelerometer random walk: | 23 mm/s/√hr VRW | 17 mm/s/√hr VRW |
| Gyroscope random walk: | 0.005 °/√h ARW | 0.001 °/√h ARW |
| Accelerometer bandwidth: | 300 Hz | 300 Hz |
| Gyroscope bandwidth: | 400 Hz | 400 Hz |
| Pressure bandwidth: | 50 Hz | 50 Hz |