
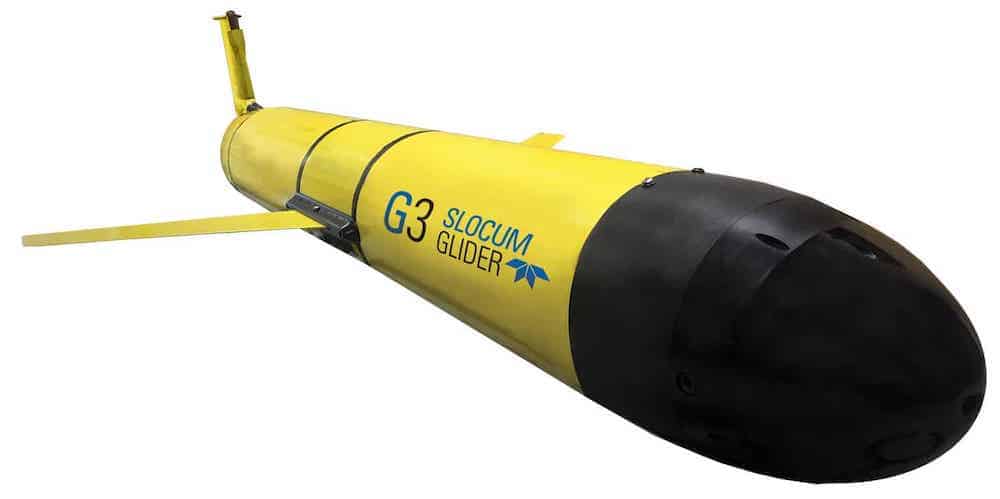
The Slocum G3 Glider from Teledyne Webb Research is a buoyancy-driven autonomous underwater vehicle engineered for long-range, extended-duration water-column observation across military, academic, and commercial operations. Its energy-efficient propulsion approach supports persistent deployments, while a modular architecture provides substantial flexibility for payload integration. A dry central payload bay is complemented by wetted areas in the bow and stern, creating multiple locations for mission-specific instrumentation. More than 40 sensor and system options are available, enabling operators to configure the vehicle around differing ocean conditions, sampling objectives, and data-collection requirements.
Designed for straightforward deployment and recovery from vessels of varying sizes, the Slocum G3 Glider minimizes required time on station while supporting remote operations after launch. Web-based piloting tools allow vehicles to be controlled from geographically separated locations, enabling multiple gliders to be managed with limited personnel and supporting infrastructure. The platform's modular construction also permits rapid sensor changes when operational requirements evolve, combining adaptable payload capacity with low-energy buoyancy propulsion for sustained autonomous monitoring.