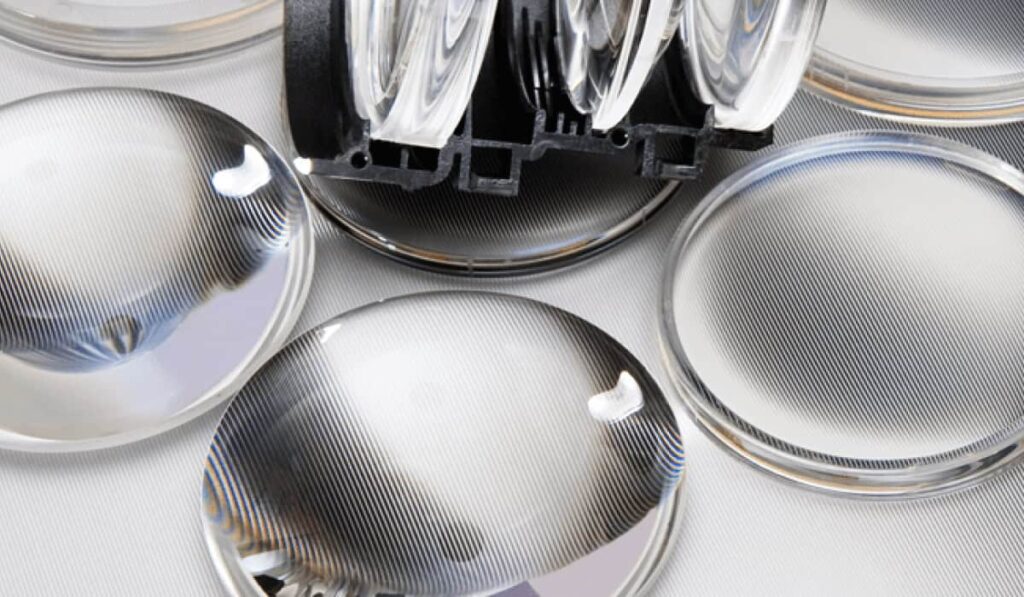
Torrent Photonics details the optical engineering challenges affecting LiDAR systems across defense and security applications. Read more >>
Low-observable targets must be acquired, operational cycles are continuous, and demanding environments create distinct optical engineering considerations. These demands vary with operating conditions.
On rotary-wing Unmanned Autonomous Vehicles (UAVs), persistent rotor-induced vibration can threaten beam alignment, while stringent Size, Weight, Power, and Cost (SWaP-C) parameters limit the optical design solutions available to address it. Fixed perimeter security installations operating 24/7 subject optics to sustained thermal stress, while spectral filtering must reject variations in solar irradiance and artificial lighting to ensure reliable detection.
Navy airborne LiDAR systems, including airborne laser mine detection commonly deployed from helicopter platforms over open sea, add salt fog, humidity, and solar glare off water surfaces to the vibration and thermal demands of airborne missions. On armored vehicles, LiDAR sensors support range finding and target tracking across broad thermal cycling, from sub-zero to elevated operating temperatures, creating a Coefficient of Thermal Expansion (CTE) mismatch between optical components and their mounts that introduces mechanical stress and positional deviation under temperature load.
Beam Steering & Optical Precision
Beam steering and the optical integrity maintained throughout the process influence whether a LiDAR system can perform reliably under these deployment conditions. Mechanical systems using rotating mirrors and galvanometers provide a wide Field of View (FoV) and high resolution, but their moving components are vulnerable to vibrational stress, shock loading, and frictional wear. Solid-state alternatives, including optical phased arrays and Micro-Electrical-Mechanical System (MEMS) mirror hybrids, eliminate the mechanical vulnerabilities associated with kinematic elements.
Regardless of the steering configuration, laser optics within the transmission and detection channels must maintain beam quality and meet tight manufacturing tolerances. Scatter, wavefront error, and filter bleed-through do not remain isolated optical problems and can propagate into the point cloud as false detections, directly degrading situational awareness in defense applications.
In defense and security applications, LiDAR rarely operates as a standalone system, instead feeding data into a multimodal fusion architecture alongside radar, electro-optical/infrared, and radio frequency sensors. Upstream optical quality determines the integrity of the combined picture, as scatter and false detections entering the fusion stack cannot be rectified during processing.
Miniaturization presents a further challenge, with smaller UAVs and autonomous vehicles pushing LiDAR onto solid-state photonic integrated circuits built on silicon photonics substrates. As optical assemblies become increasingly compact and physical margins shrink, fabrication tolerances become more critical.
Defining LiDAR Optical Specifications
For OEMs, these optical demands translate into engineering decisions that must be defined before component selection begins. The first and most consequential is laser wavelength, with LiDAR systems commonly operating at near-infrared wavelengths of 905nm or 1550nm. Wavelength drives downstream specifications including detector type, filter center wavelength, coating parameters, and permissible pulse energy.
The platform’s operating environment governs coating durability requirements, substrate selection, mounting tolerances, and the SWaP-C envelope. Defining optics before these constraints have been established risks incompatibilities that cannot be corrected at component level. Establishing wavelength and deployment environment at the outset therefore provides OEM designers and engineers with a fixed framework around which the optical specification can be developed.
Read ‘LiDAR in Modern Defense & Security‘ for more information.