
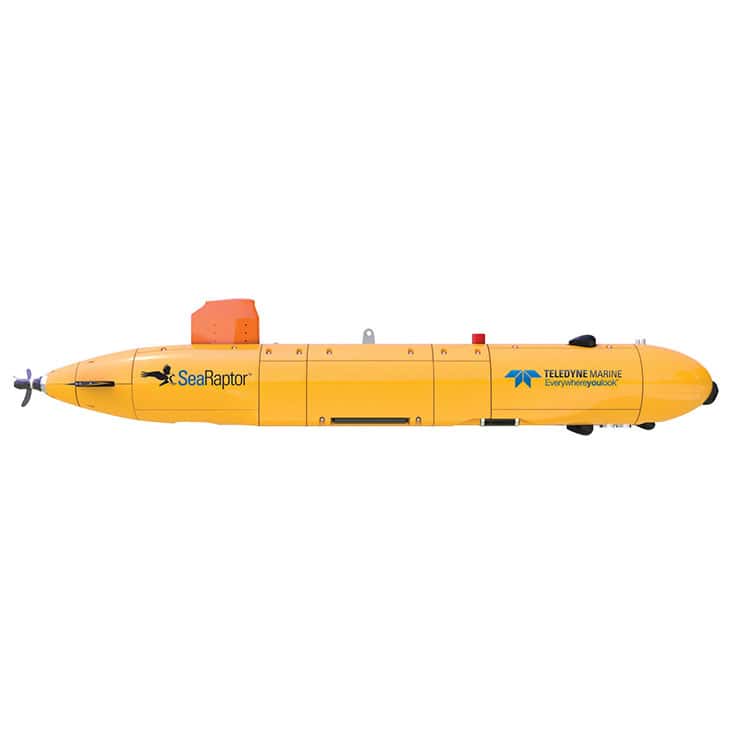
The SeaRaptor AUV is a survey-grade deep-water autonomous underwater vehicle offered with 3,000 m and 6,000 m depth ratings for operations at abyssal depths. Designed around a flexible payload architecture, the vehicle incorporates multiple ports supplying serial communications, Ethernet connectivity, and electrical power for field-swappable sensing equipment. Available integrations include side-scan sonar, multibeam echo sounders, sub-bottom profilers, high-resolution cameras, laser scanners, strobes, CTD instrumentation, and forward-looking sonar, with custom sensor integration also supported. Removable battery packs and data storage help accelerate mission turnaround, while standard and extended battery capacities support endurance of approximately 24 hours at 3 knots, depending on configuration and payload.
Navigation equipment includes an inertial navigation system, DVL, depth sensing, and GNSS, together with support for optional USBL or bottom-mounted LBL acoustic aiding during extended submerged operations. SeaRaptor can conduct broad-area searches, hydrographic mapping, and detailed optical or acoustic inspection, supporting missions such as search and recovery, salvage, exploration, construction support, marine archaeology, and oceanographic survey. Multiple emergency provisions, including an acoustic pinger, drop-weight release, satellite locator beacon, and RF beacon, provide alternative recovery methods above and below the surface. Vehicle control and mission preparation use software derived from the established Gavia AUV platform, combining chart-based planning with vehicle operation, data retrieval, and post-mission analysis.