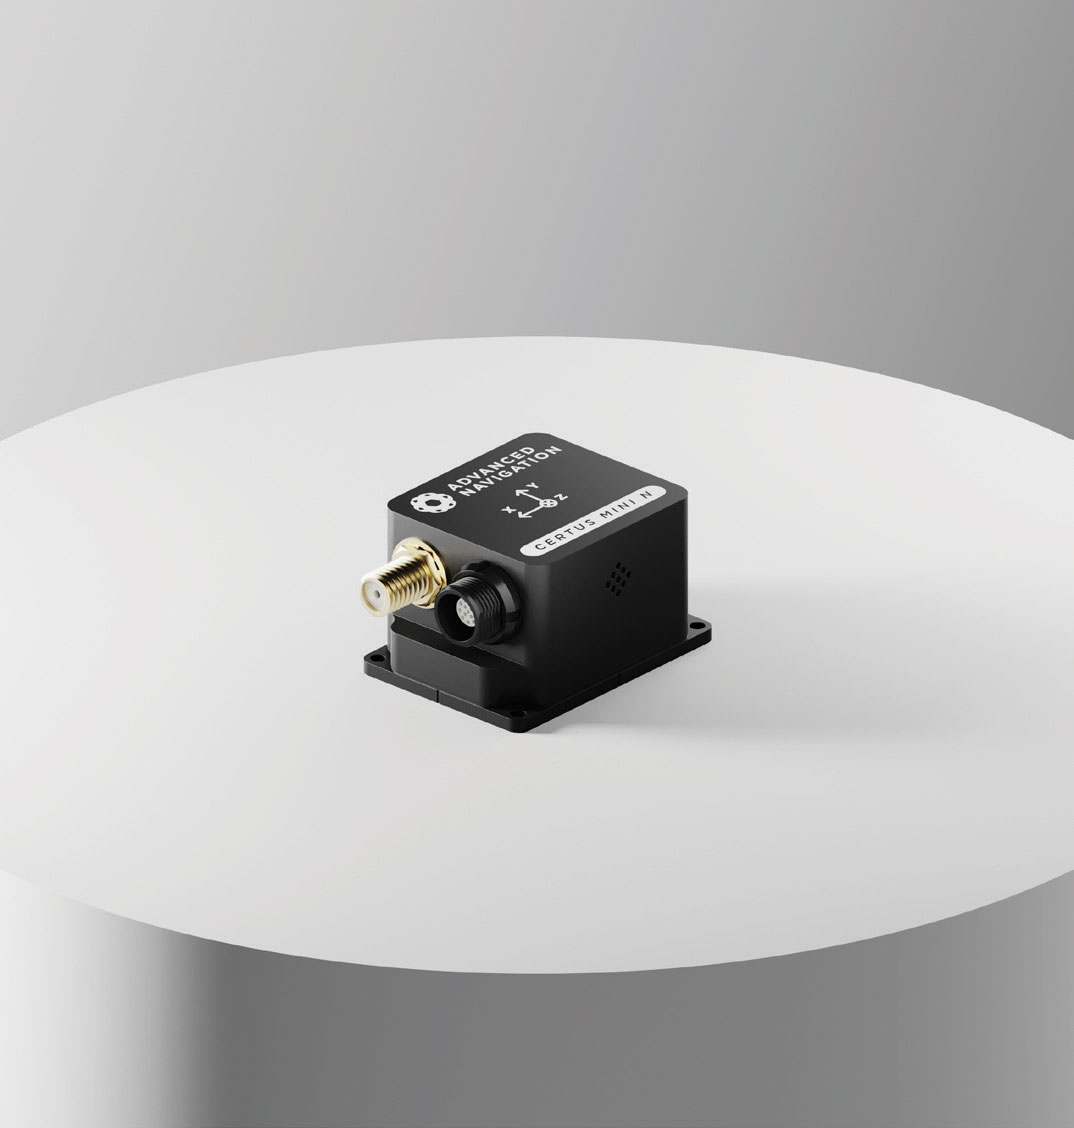
Certus Mini N from Advanced Navigation is a miniature, single-antenna MEMS GNSS/INS designed to provide position, velocity, acceleration, and orientation data in demanding operating conditions. Temperature-calibrated accelerometers, gyroscopes, pressure sensing, and magnetometers are combined with an L1/L5 multi-constellation GNSS receiver through an AI-based fusion algorithm. The system supports GPS, GLONASS, Galileo, BeiDou, NavIC, and SBAS, with RTK horizontal positioning accuracy of 0.01 m, roll and pitch accuracy of 0.1°, velocity-based heading accuracy of 0.2°, and output rates up to 500 Hz.
Built around low SWaP-C integration, Certus Mini N is offered in rugged and OEM configurations. The rugged unit measures 30 × 41 × 24 mm, weighs 43 g, operates from 5 to 36 V, and carries IP67 ingress protection, while the OEM version measures 25 × 25 × 10 mm, weighs 8 g, and operates from 5 V. Communication options include RS232, RS422, UART, CAN, GPIO, ANPP, NMEA, CANOpen, 1PPS, RTCM, odometer or air-data input, DVL, and USBL. Supported applications include UAV navigation, georeferencing, stabilisation and pointing, ground-vehicle navigation, robotics control, AUV navigation, ROV navigation, and hydrography.
| Horizontal position accuracy: | 1.5 m |
| Vertical position accuracy: | 2.0 m |
| Horizontal position accuracy with SBAS: | 0.7 m |
| Vertical position accuracy with SBAS: | 0.8 m |
| Horizontal position accuracy with RTK: | 0.01 m |
| Vertical position accuracy with RTK: | 0.015 m |
| Velocity accuracy: | 0.05 m/s |
| Roll and pitch accuracy: | 0.1° |
| Heading accuracy, velocity: | 0.2° |
| Heading accuracy, magnetic only: | 0.8° |
| Heave accuracy: | 5% or 0.05 m, whichever is greater |
| Orientation range: | Unlimited |
| Hot-start filter initialisation: | 1 s |
| Output data rate: | Up to 500 Hz |
| Model: | L1/L5 GNSS |
| Supported navigation systems: | GPS L1C/A, L5; GLONASS L1OF; Galileo E1B/C, E5a; BeiDou B1I, B2a; NavIC L5 SPS |
| Supported SBAS systems: | WAAS, EGNOS, MSAS, GAGAN, and QZSS |
| Update rate: | Up to 25 Hz |
| Hot-start first fix: | 3 s |
| Timing accuracy: | 30 ns RMS |
| Operating voltage, rugged: | 5 to 36 V |
| Operating voltage, OEM: | 5 V |
| Typical power consumption, rugged: | 0.9 W |
| Typical power consumption, OEM: | 0.5 W |
| Hot start enabled: | Yes |
| Operating temperature: | -40°C to 85°C |
| Ingress protection, rugged: | IP67 |
| Shock limit, IEC 60068-2-27: | 150 g, 6 ms |
| Shock limit, MIL-STD-810H 516.8: | 40 g, 11 ms |
| Vibration limit, MIL-STD-810H 514.8: | 7.7 g RMS |
| Dimensions, rugged: | 30 × 41 × 24 mm |
| Dimensions, OEM: | 25 × 25 × 10 mm |
| Weight, rugged: | 43 g |
| Weight, OEM: | 8 g |
| Interfaces, rugged: | Primary RS232/RS422, auxiliary RS232, CAN, and 2× GPIO |
| Interfaces, OEM: | Primary and auxiliary UART, CAN, and 2× GPIO |
| Protocols and functions: | Digital input/output, frequency input, AN Packet Protocol (ANPP), NMEA, GNSS, CANOpen, 1PPS, odometer/air data, DVL/USBL, and RTCM |
| Accelerometer range: | ±2 g, ±4 g, and ±16 g |
| Gyroscope range: | ±250°/s, ±500°/s, and ±2000°/s |
| Magnetometer range: | ±8 G |
| Pressure range: | 30 to 125 kPa |
| Accelerometer initial bias: | <5 mg |
| Gyroscope initial bias: | <0.2°/s |
| Pressure initial bias: | <6 Pa |
| Accelerometer initial scaling error: | <0.06% |
| Gyroscope initial scaling error: | <0.04% |
| Magnetometer initial scaling error: | <0.07% |
| Accelerometer scale factor stability: | <0.06% |
| Gyroscope scale factor stability: | <0.05% |
| Magnetometer scale factor stability: | <0.09% |
| Accelerometer non-linearity: | <0.05% |
| Gyroscope non-linearity: | <0.05% |
| Magnetometer non-linearity: | <0.08% |
| Cross-axis alignment error: | <0.05° for accelerometers, gyroscopes, and magnetometers |
| Accelerometer noise density: | 100 µg/√Hz |
| Gyroscope noise density: | 0.004°/s/√Hz |
| Magnetometer noise density: | 210 µG/√Hz |
| Pressure noise density: | 0.08 Pa/√Hz |
| Accelerometer random walk: | 58 mm/sec/√hr VRW |
| Gyroscope random walk: | 0.24°/√h ARW |
| Accelerometer bandwidth: | 400 Hz |
| Gyroscope bandwidth: | 400 Hz |
| Magnetometer bandwidth: | 110 Hz |